Linux Kernel 6.12 Merges Real-Time PREEMPT_RT: What Decades in the Making Means for Robotics and Low-Latency Servers
After nearly two decades of maintenance as an external patch series, PREEMPT_RT has officially been merged into mainline Linux 6.12, bringing deterministic latency guarantees to industrial computing.

Deterministic kernel preemption lands natively in the mainline Linux tree without out-of-tree patches.
In what engineers are celebrating as one of the most historic milestones in open-source operating system history, Linus Torvalds and the core kernel team have officially merged the PREEMPT_RT (Real-Time) patch set into mainline Linux 6.12. For the first time, developers can compile a standard Linux kernel with full hard real-time capabilities without relying on third-party patch sets.
Mainline Determinism vs. Best-Effort Scheduling
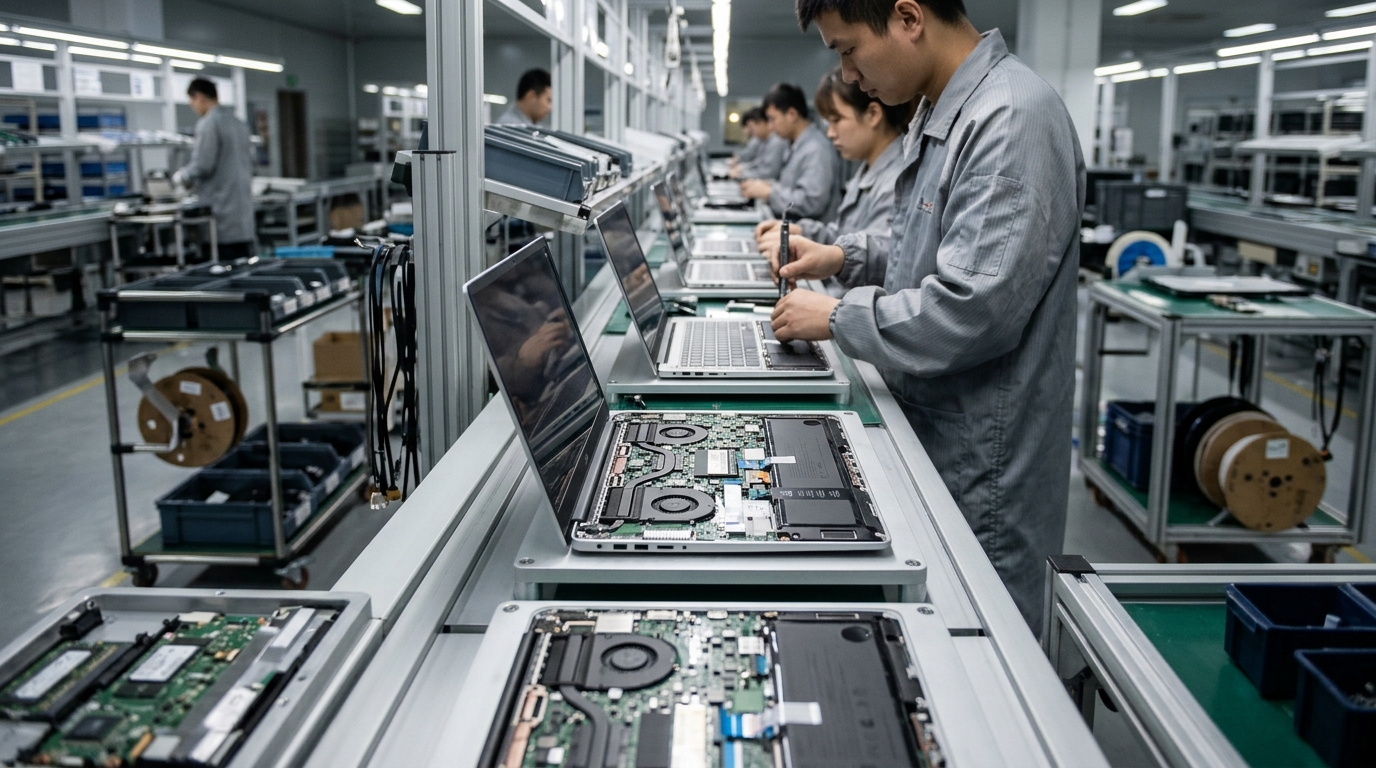
Standard general-purpose operating systems optimize for overall throughput: they happily delay a process by a few milliseconds if it allows for more efficient batch caching or hardware context switching. In high-frequency trading, autonomous robotics, medical avionics, and industrial automation, however, a late response is functionally equivalent to an error.
PREEMPT_RT converts spinlocks into preemptible sleeping locks, prioritizes interrupt handlers as schedulable kernel threads, and implements priority inheritance to eliminate priority inversion deadlocks. This guarantees deterministic upper-bound scheduling latencies under peak computational load.
Accelerating Python with Rust: Architecting High-Throughput Data Pipelines Using PyO3 and Polars
Next Dispatch →The Shift to Test-Time Compute: Why Reasoning Models Are Changing the Economics of LLM Inference
Discussion (0)
Technical commentaryLeave a Reply
No comments yet. Be the first to share your thoughts!